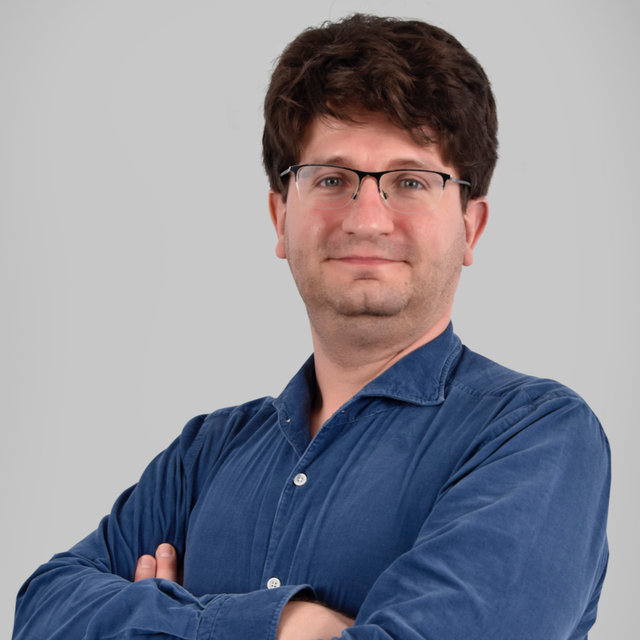
Eliseo Ferrante
Roboticist · AI & Swarm Intelligence

Research profile
My research is on embodied collective intelligence: how groups of robots can coordinate, make decisions and adapt using local information and decentralized interactions. I combine swarm robotics, collective behaviour, machine learning and automatic design, from fundamental models of self-organization to multi-UAV systems validated in real-world environments.
My work connects mathematical models and computer simulations with experiments on real robots, including decentralized aerial swarms that operate without relying on GNSS or centralized control. I received my PhD from Université Libre de Bruxelles in 2013 and have co-authored more than 80 scientific publications across robotics, AI and complex systems. Explore my research and publications for projects and published results.